Robotics · Human–Robot Interaction

Yanwen Zou 邹砚文

I'm a Ph.D. student of Shanghai Jiaotong University, advised by Prof. Cewu Lu and Prof. Chuan Wen. I got MEng degree from The Department of Mechanical Engineering at UC Berkeley, where I was fortunate to cooperate with PhDs and postdocs in MSC Lab led by Prof. Masayoshi Tomizuka.

Before my journey at Berkeley, I received my Bachelor's degree from School of Mechanical and Engineering, Qian Xuesen Class at Shanghai Jiaotong University. After graduation, I studied Finance at SAIF at Shanghai Jiaotong University and then dropped out.

I'm now building general physical intelligence at Noematrix Lab. I believe we cannot directly deploy fully autonomous robot from lab to home in the near future. Let's chat if you are also interested in human-robot interaction, agentic robotics, and policy steering.

Previously, I also interned at Prof. Bo Zhao's lab, Grasp Lab at Zhejiang University, advised by Prof. Huixu Dong, and robotics startup Maxinsights.

Yanwen Zou holding a paper airplane outdoors

Research

Human-Robot Interaction, Policy Steering, and Agentic Robotics. All about human.

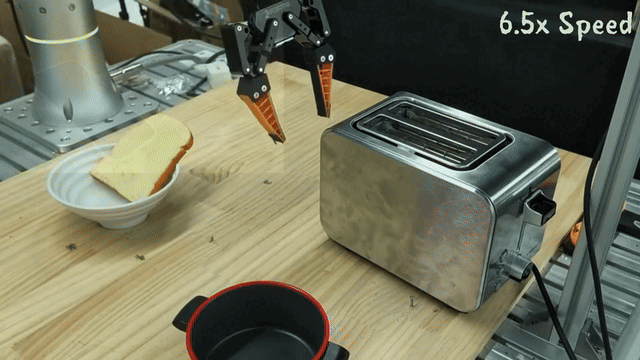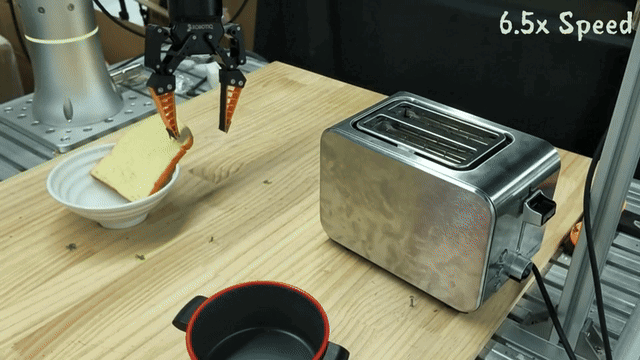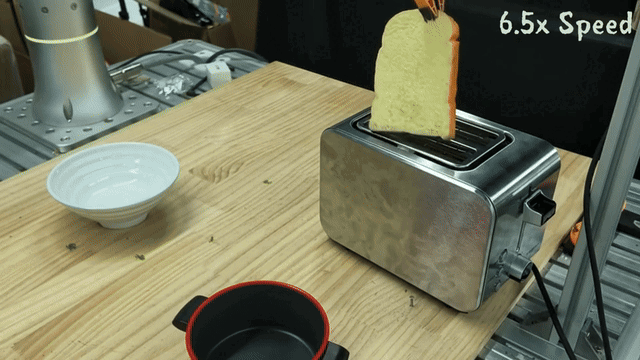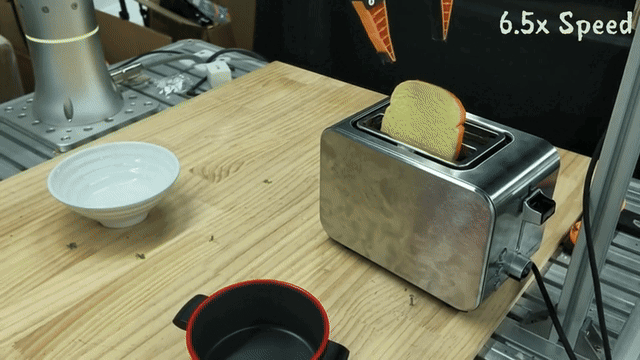
RoboPrompt bread steering demonstration

RoboPrompt: Intuitive Robot Policy Steering with Sparse Human Input

arXiv, 2026

Project page arXiv

RoboPrompt lets users steer diffusion and flow-matching robot policies with sparse target points, drawn traces, and coarse directional guidance. A reusable module turns human intent into action drafts that the base policy refines, enabling intuitive failure recovery and policy improvement through steered rollouts.
Evo-1 model framework

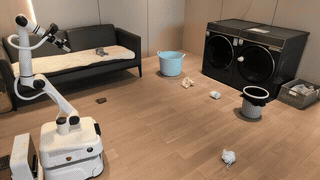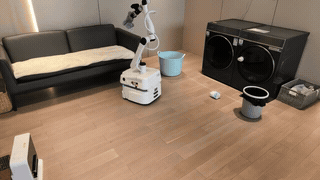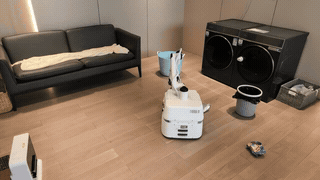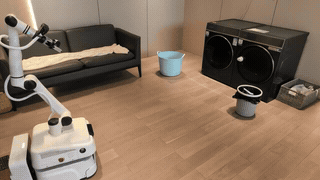
Evo-1: Lightweight Vision-Language-Action Model with Preserved Semantic Alignment

CVPR 2026

Project page arXiv

Evo-1 builds on a native multimodal Vision-Language model (VLM), incorporating a novel cross-modulated diffusion transformer along with an optimized integration module, together forming an effective architecture. With only 0.77 billion parameters, Evo-1 achieves SOTA results on the Meta-World and RoboTwin suite.

U-ARM teleoperation demo

U-ARM: Ultra low-cost general teleoperation interface for robot manipulation

RSS 2026 RoboData Workshop

Project page arXiv

U-Arm is a low-cost, universal, leader-follower teleoperation system for any commercial robot arms through three hardware configurations. Designed for researchers, educators, and robotics enthusiasts, it provides a standardized interface for diverse robot platforms.

Projects

Selected systems, prototypes, and things made for research or simply for fun.

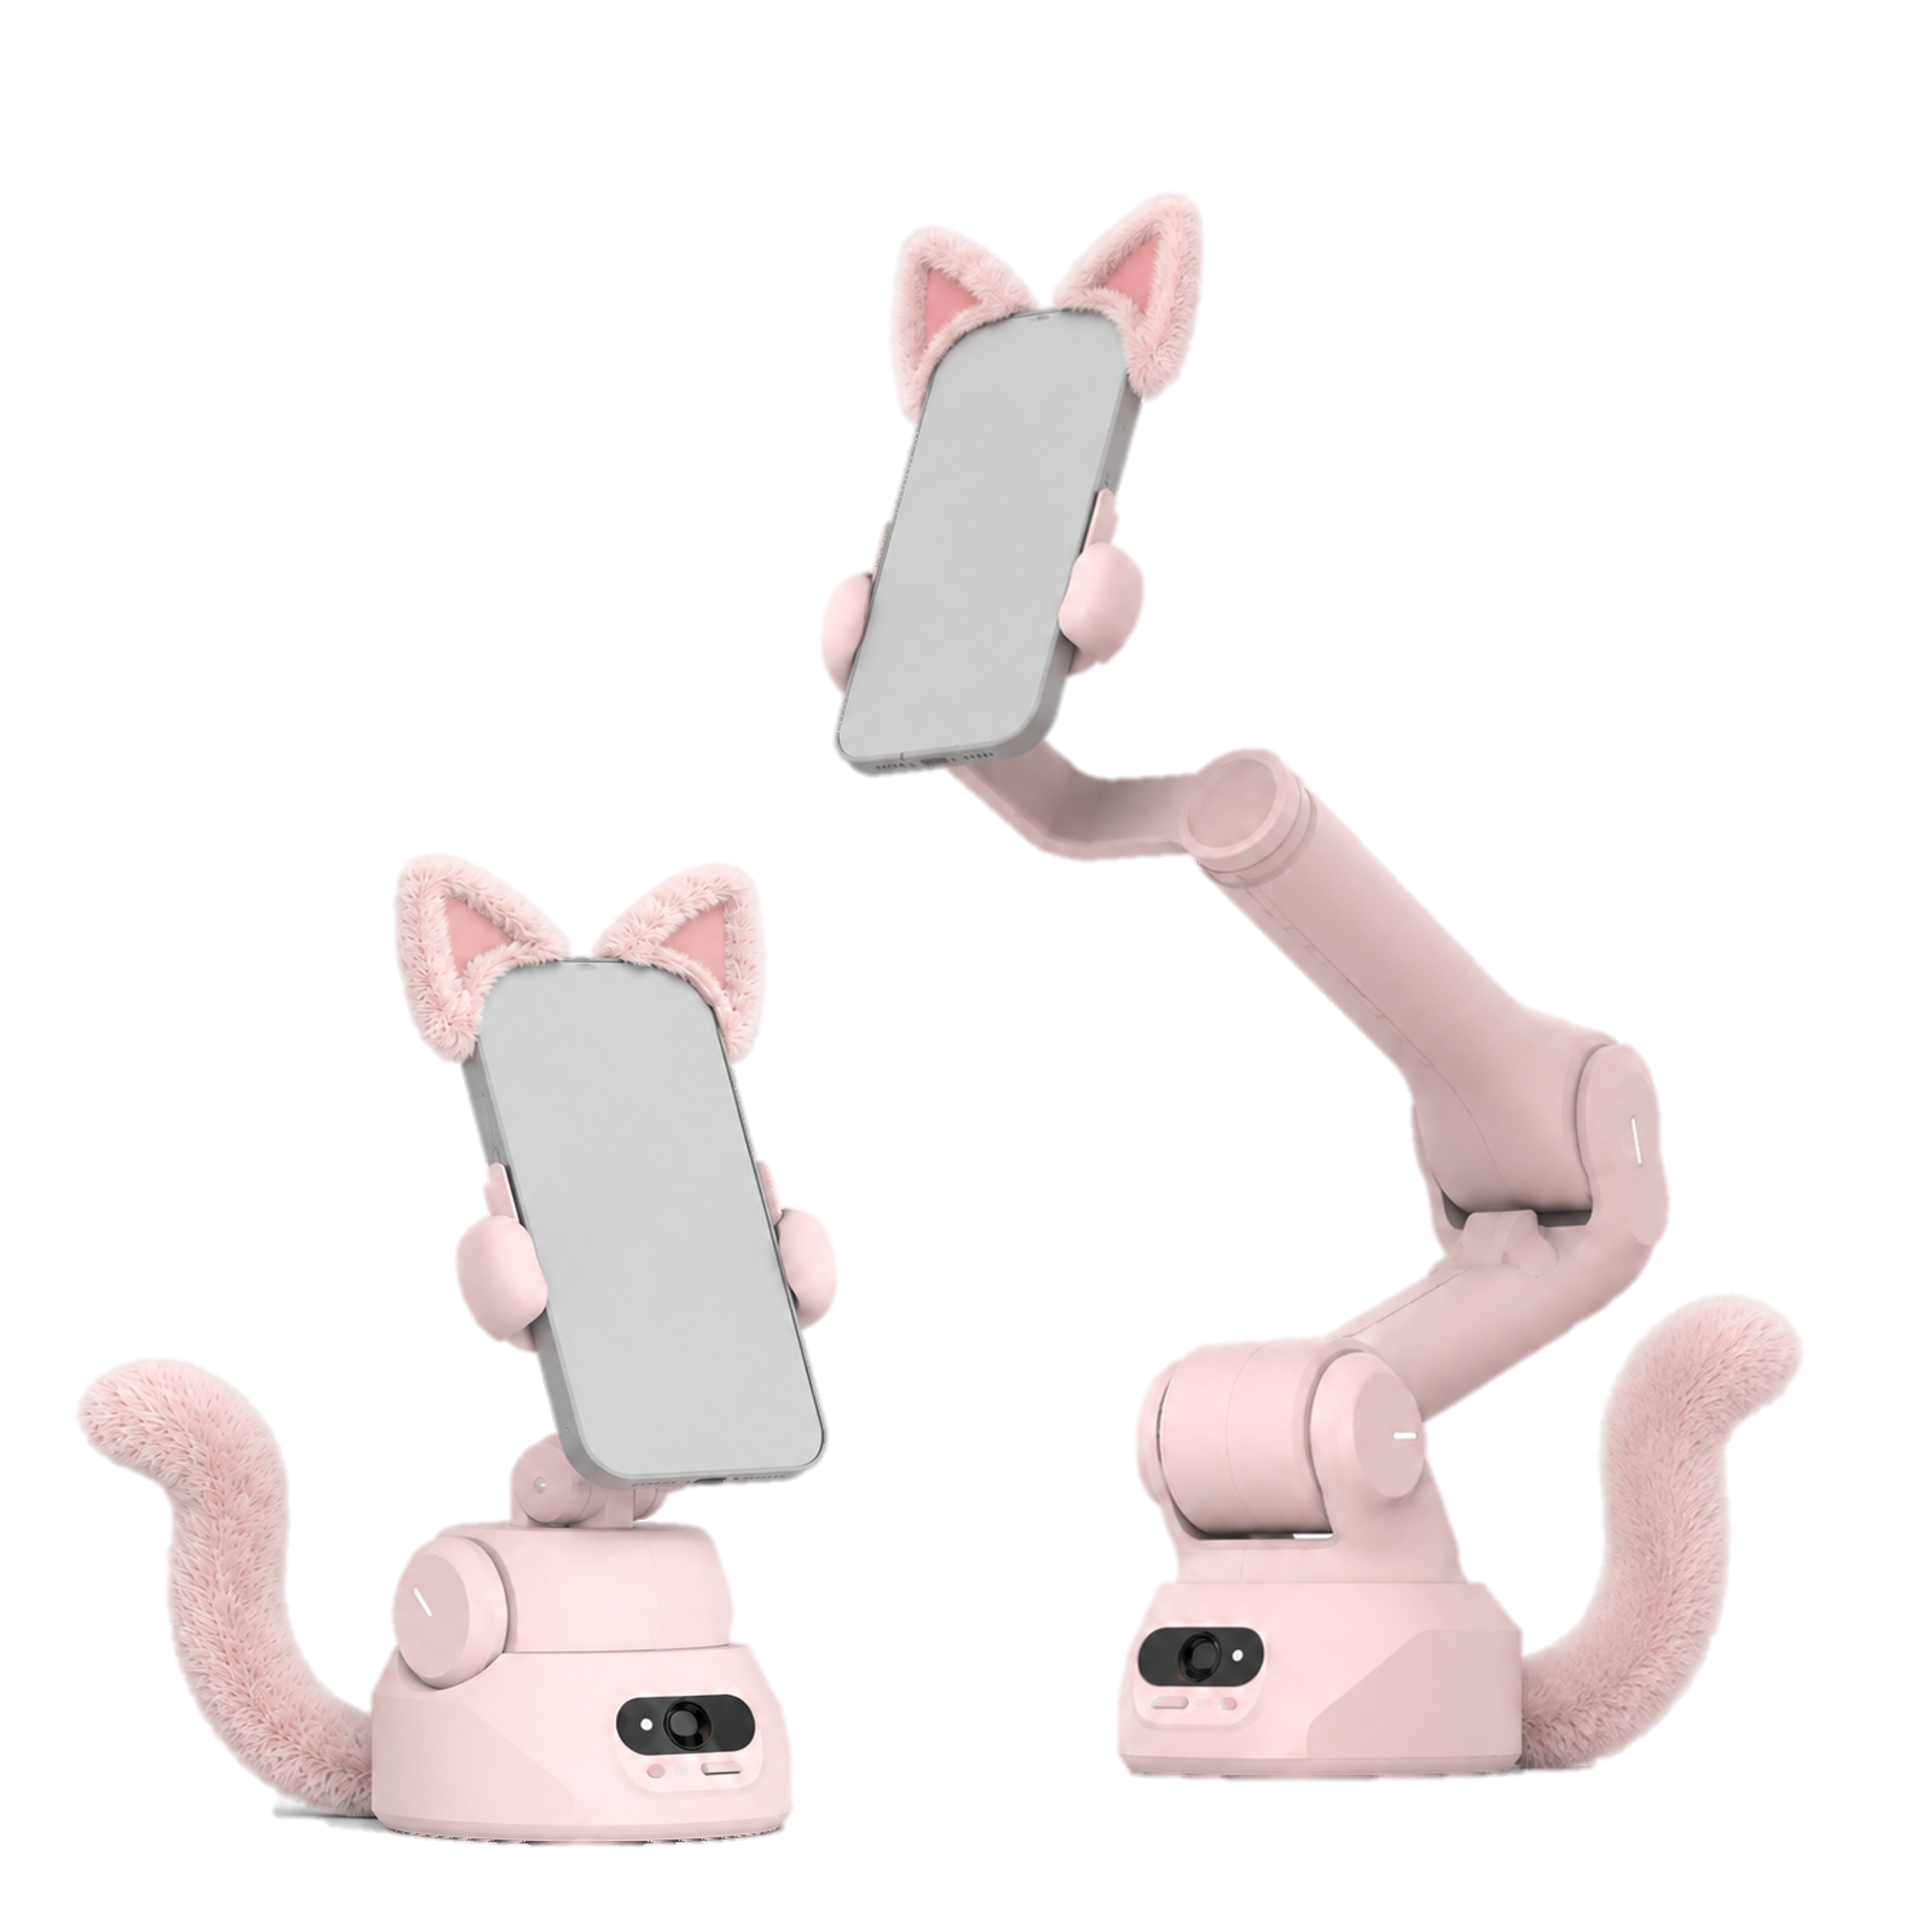
WooLoong desktop robotic camera arm for smartphone photography

WooLoong: A Little Camera Crew for Your Desk

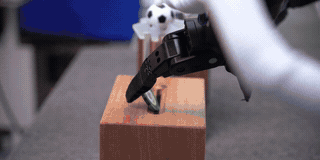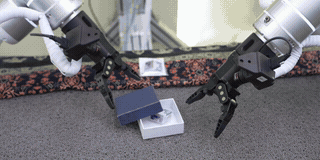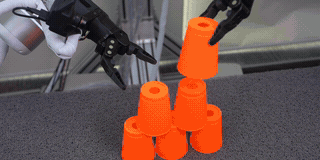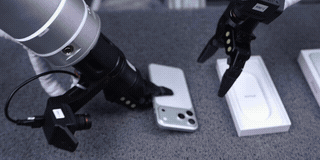
A desktop robotic arm for smartphone photography hobbyists. Let the arm handle the camera moves while you focus on the shot. We developed the full stack in-house to bring the complete system's retail price below RMB 6,000. Tiny camera crew, tiny budget, surprisingly fluffy ears.

Elisabeth (伊丽莎白)

Elisabeth from Gintama, now hanging out on my desk. A little character-inspired desk ornament, made just for fun. No grand robotics mission here, just a very important desk companion.

Flying robot inspired by Apocalypse Hotel

Flycatcher Robot (ハエトリロボ)

RedNote

A character in Apocalypse Hotel (末日后酒店). 3D-printed and controlled through a game controller.

Dexterous hand prototype

Tendon-driven Dexterous Hand and Wearable Finger

Each finger has flexion and lateral DoF with torsion springs incorporated into every joint. The current configuration still has limited payload. Assembly remains a maddening job thanks to all the tendons.

Amphibious fixed-wing aircraft prototype

Amphibious Fixed-wing Aircraft

An undergraduate class project. We designed turbines that adapt to both water and air, and integrated the system on top of an open-source flight control board. It hit a tree during takeoff, but we still believe it could fly.

I am accompanied with